The Physical AI Blueprint
The Physical AI Blueprint
Building Real-World Intelligence Through Reasoning, Not Brute-Force Data
Physical AI is the intelligence that lets machines perceive, reason, and act in the physical world. Unlike intelligence built around tokens in the cloud, it must operate in a continuous, dynamic environment governed by physics, geometry, and real-time constraints.
This is why simply repeating the scaling playbook of digital AI is not enough. Robots do not have access to internet-scale datasets of physical interaction, nor can they depend on millions of real-world trials for every new task or environment.
Physical AI must scale by design, not simply by data volume.
That requires models that reason about physics, maintain an understanding of the world over time, expose critical reasoning steps for validation, and adapt to new tasks with dramatically less data.
This is our blueprint for building the next generation of intelligent robots, and unlocking a $10 trillion opportunity as AI moves from the digital world into the physical one.
01
Why Robots, Why Now?
The case for robotics has never been stronger. Labor shortages, aging populations, and supply chain fragility are straining industries worldwide. In sectors such as agriculture, logistics, manufacturing, and construction, the gap between available labor and operational demand continues to widen, making automation an economic necessity rather than a luxury.
At the same time, the technology has reached an inflection point. Better sensors, more capable robots, specialized edge compute, and advances in AI are converging to enable machines that are far more intelligent and adaptable than previous generations.
The opportunity is no longer simply to automate repetitive motion. It is to build machines that can understand changing environments, make decisions, and adapt their behavior in the real world.
02
Why Brute-Force Data Scaling Breaks in the Physical World
Most robots still work best in controlled environments. Reality is different: lighting changes, objects arrive in unfamiliar configurations, surfaces deform, equipment wears, and people move unpredictably through the scene.
A model that is 99% accurate looks impressive in a demo. But if a robot makes 10,000 decisions in a shift, that error rate translates to 100 failures.
In the physical world, a single failure can halt a line, damage equipment, or create a safety risk.
The natural instinct is to follow the digital AI playbook: collect more data and train larger models. But digital AI was built on decades of human-generated internet data. The physical world has no equivalent, and collecting millions of examples for every robot, task, and environment is prohibitively expensive.
Physical AI therefore needs a different path: high reliability and generalization without unbounded data requirements.
03
Building Intelligence That Works in the Physical World
Physical AI requires more than a capable model. It requires an architecture designed around the constraints of the physical world: persistent world understanding, reliable and inspectable reasoning, compositional intelligence, and real-time execution on the machine.
The following principles form the architecture for building intelligence that can move from a model in the cloud to reliable autonomy in the real world.
03.1
World-Reasoning Models: From Seeing to Acting
At the core of Physical AI are multimodal models that connect perception, reasoning, and action. But recognizing what is in a scene is not enough. A robot needs a persistent representation of the physical world: what exists, how it is changing, and what is likely to happen next.
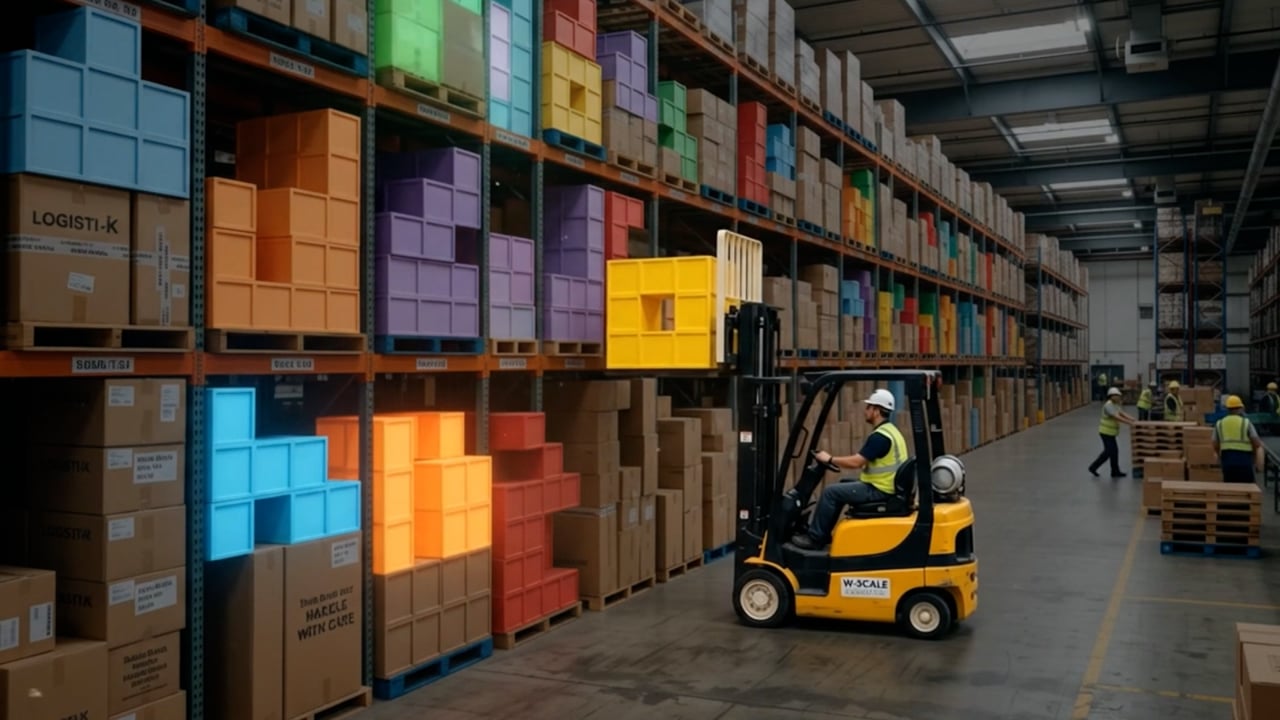
Traditional robotics maintained estimates of robot and world state for planners and controllers. World models extend this idea into something richer. An object that disappears behind an occlusion does not cease to exist. A moving forklift continues along a trajectory even when it leaves the camera view. And every action a robot takes changes the set of actions available next.
This is also where world reasoning extends beyond the basic promise of Vision-Language-Action (VLA) models. VLAs connect perception and action within a shared model, but Physical AI needs more than mapping observations to actions. It needs to maintain state over time, model how the world evolves, and reason about the consequences of candidate actions before executing them.
A world model therefore represents not just the current scene, but how that scene is likely to evolve. This creates a space in which the robot can evaluate candidate actions before committing to one: what happens if it grasps here, moves this way, applies this force, or waits a moment longer.
The same representation that lets a robot track the world through uncertainty can therefore support planning and action within it.
Perception tells a robot what is there. A world-reasoning model helps it understand what happens next and what to do about it.
03.2
Reliable by Design at the Edge
In the physical world, even small errors have consequences. Robots must perform correctly, predictably, and explainably. Each decision, whether a grasp, a turn, or a stop, must be auditable, measurable, and consistent across conditions.
This is why reliability is a design constraint, built in from the start rather than measured at the end.
When a robot drops a package, the failure could sit in perception, reasoning, control, or hardware, and a monolithic model makes those failures difficult to isolate.
Reliability therefore has to be engineered into the structure of the system. Critical reasoning steps can be inspected and independently checked against physical and safety constraints before execution, while components can be tested in isolation and decisions logged as they happen.
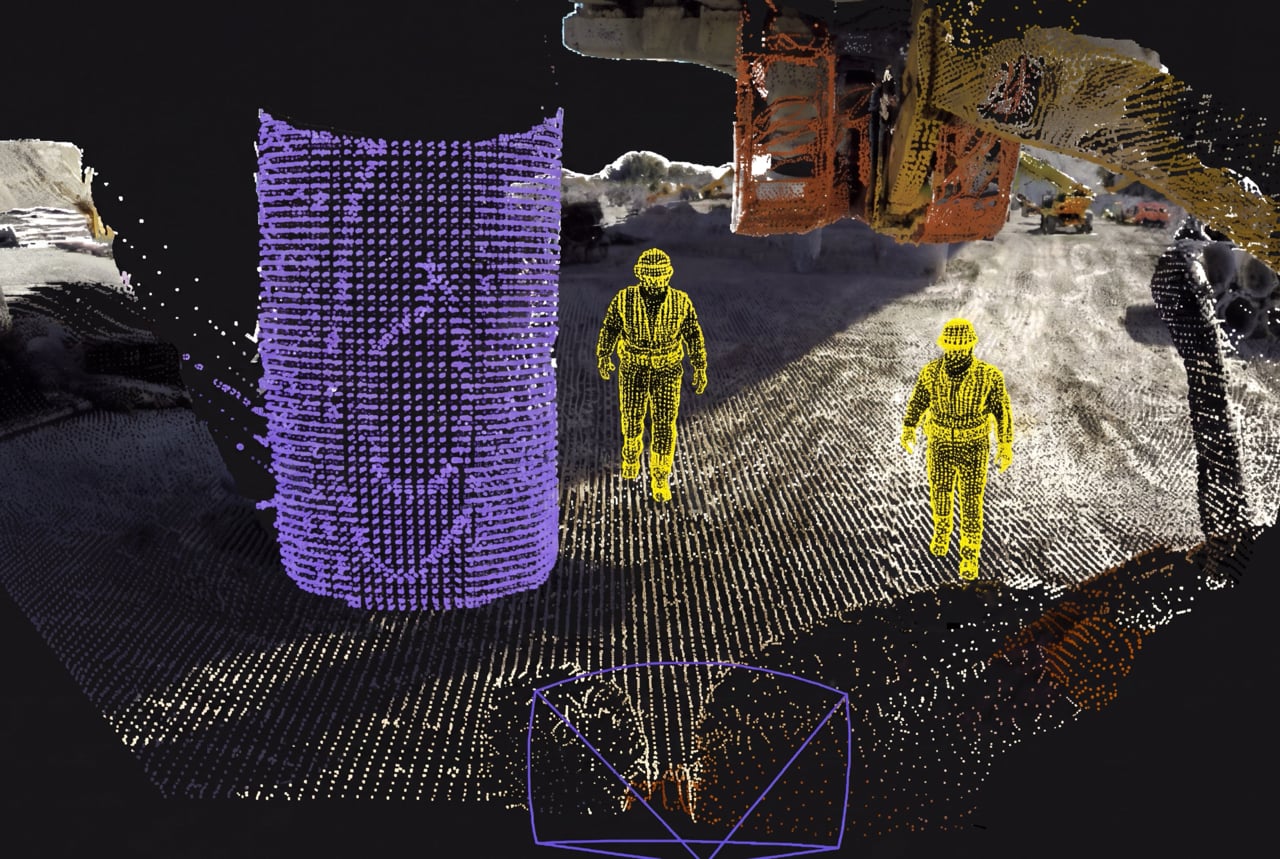
This architecture also has to work where the robot operates: at the edge and in real time. Physical machines cannot depend on a cloud round trip for every decision. Perception, reasoning, and action must operate within the latency of the physical process itself, whether that means milliseconds for a moving robot or a slower loop for inspection and planning. Models must remain responsive when connectivity disappears and degrade safely when compute resources are constrained.
Reliable Physical AI is therefore both a model and systems problem. Intelligence must be inspectable, constrained, and designed to run on the machine itself.
03.3
Thin Agents, Shared Intelligence
Traditional robotic systems are often assembled from separate models for perception, planning, control, and individual tasks, each trained and maintained independently. Physical AI creates the opportunity to replace much of that fragmentation with a shared foundation model that carries knowledge and reasoning across capabilities.
But shared intelligence does not have to mean a monolithic system. Thin agents for perception, planning, control, or task-specific reasoning can interface with the same core model, providing the context, constraints, tools, and objectives needed for a particular capability.
This preserves the advantages of a single shared intelligence, where learning can transfer across tasks, while retaining the compositionality and interpretability needed to build and debug real robotic systems. New capabilities can be added at the edges without building or retraining a separate foundation model for every task.
The result is intelligence that scales by composition: one shared foundation, specialized through thin, interpretable agents.
04
Physics Reasoning: 300 Examples, Not Millions
If brute force data collection is off the table, something else has to carry the weight. That something is physics.
Gravity, friction, contact, geometry, and motion behave the same way in a warehouse in Memphis and a field in Iowa. A model that learns this underlying structure does not need to relearn it every time the environment changes.
What changes from deployment to deployment is the configuration: the objects, lighting, geometry, equipment, and tolerances of the task. The underlying physical principles remain.
This separation between what stays constant and what changes is what makes data efficiency possible. Learn the structure once, then adapt to a new task or environment with a fraction of the data.
04.1
Structure Beats Memorization
The physical world is not an arbitrary collection of patterns. It has structure. Objects have relationships, actions have consequences, and most constraints interact with only a small part of the world at any given moment.
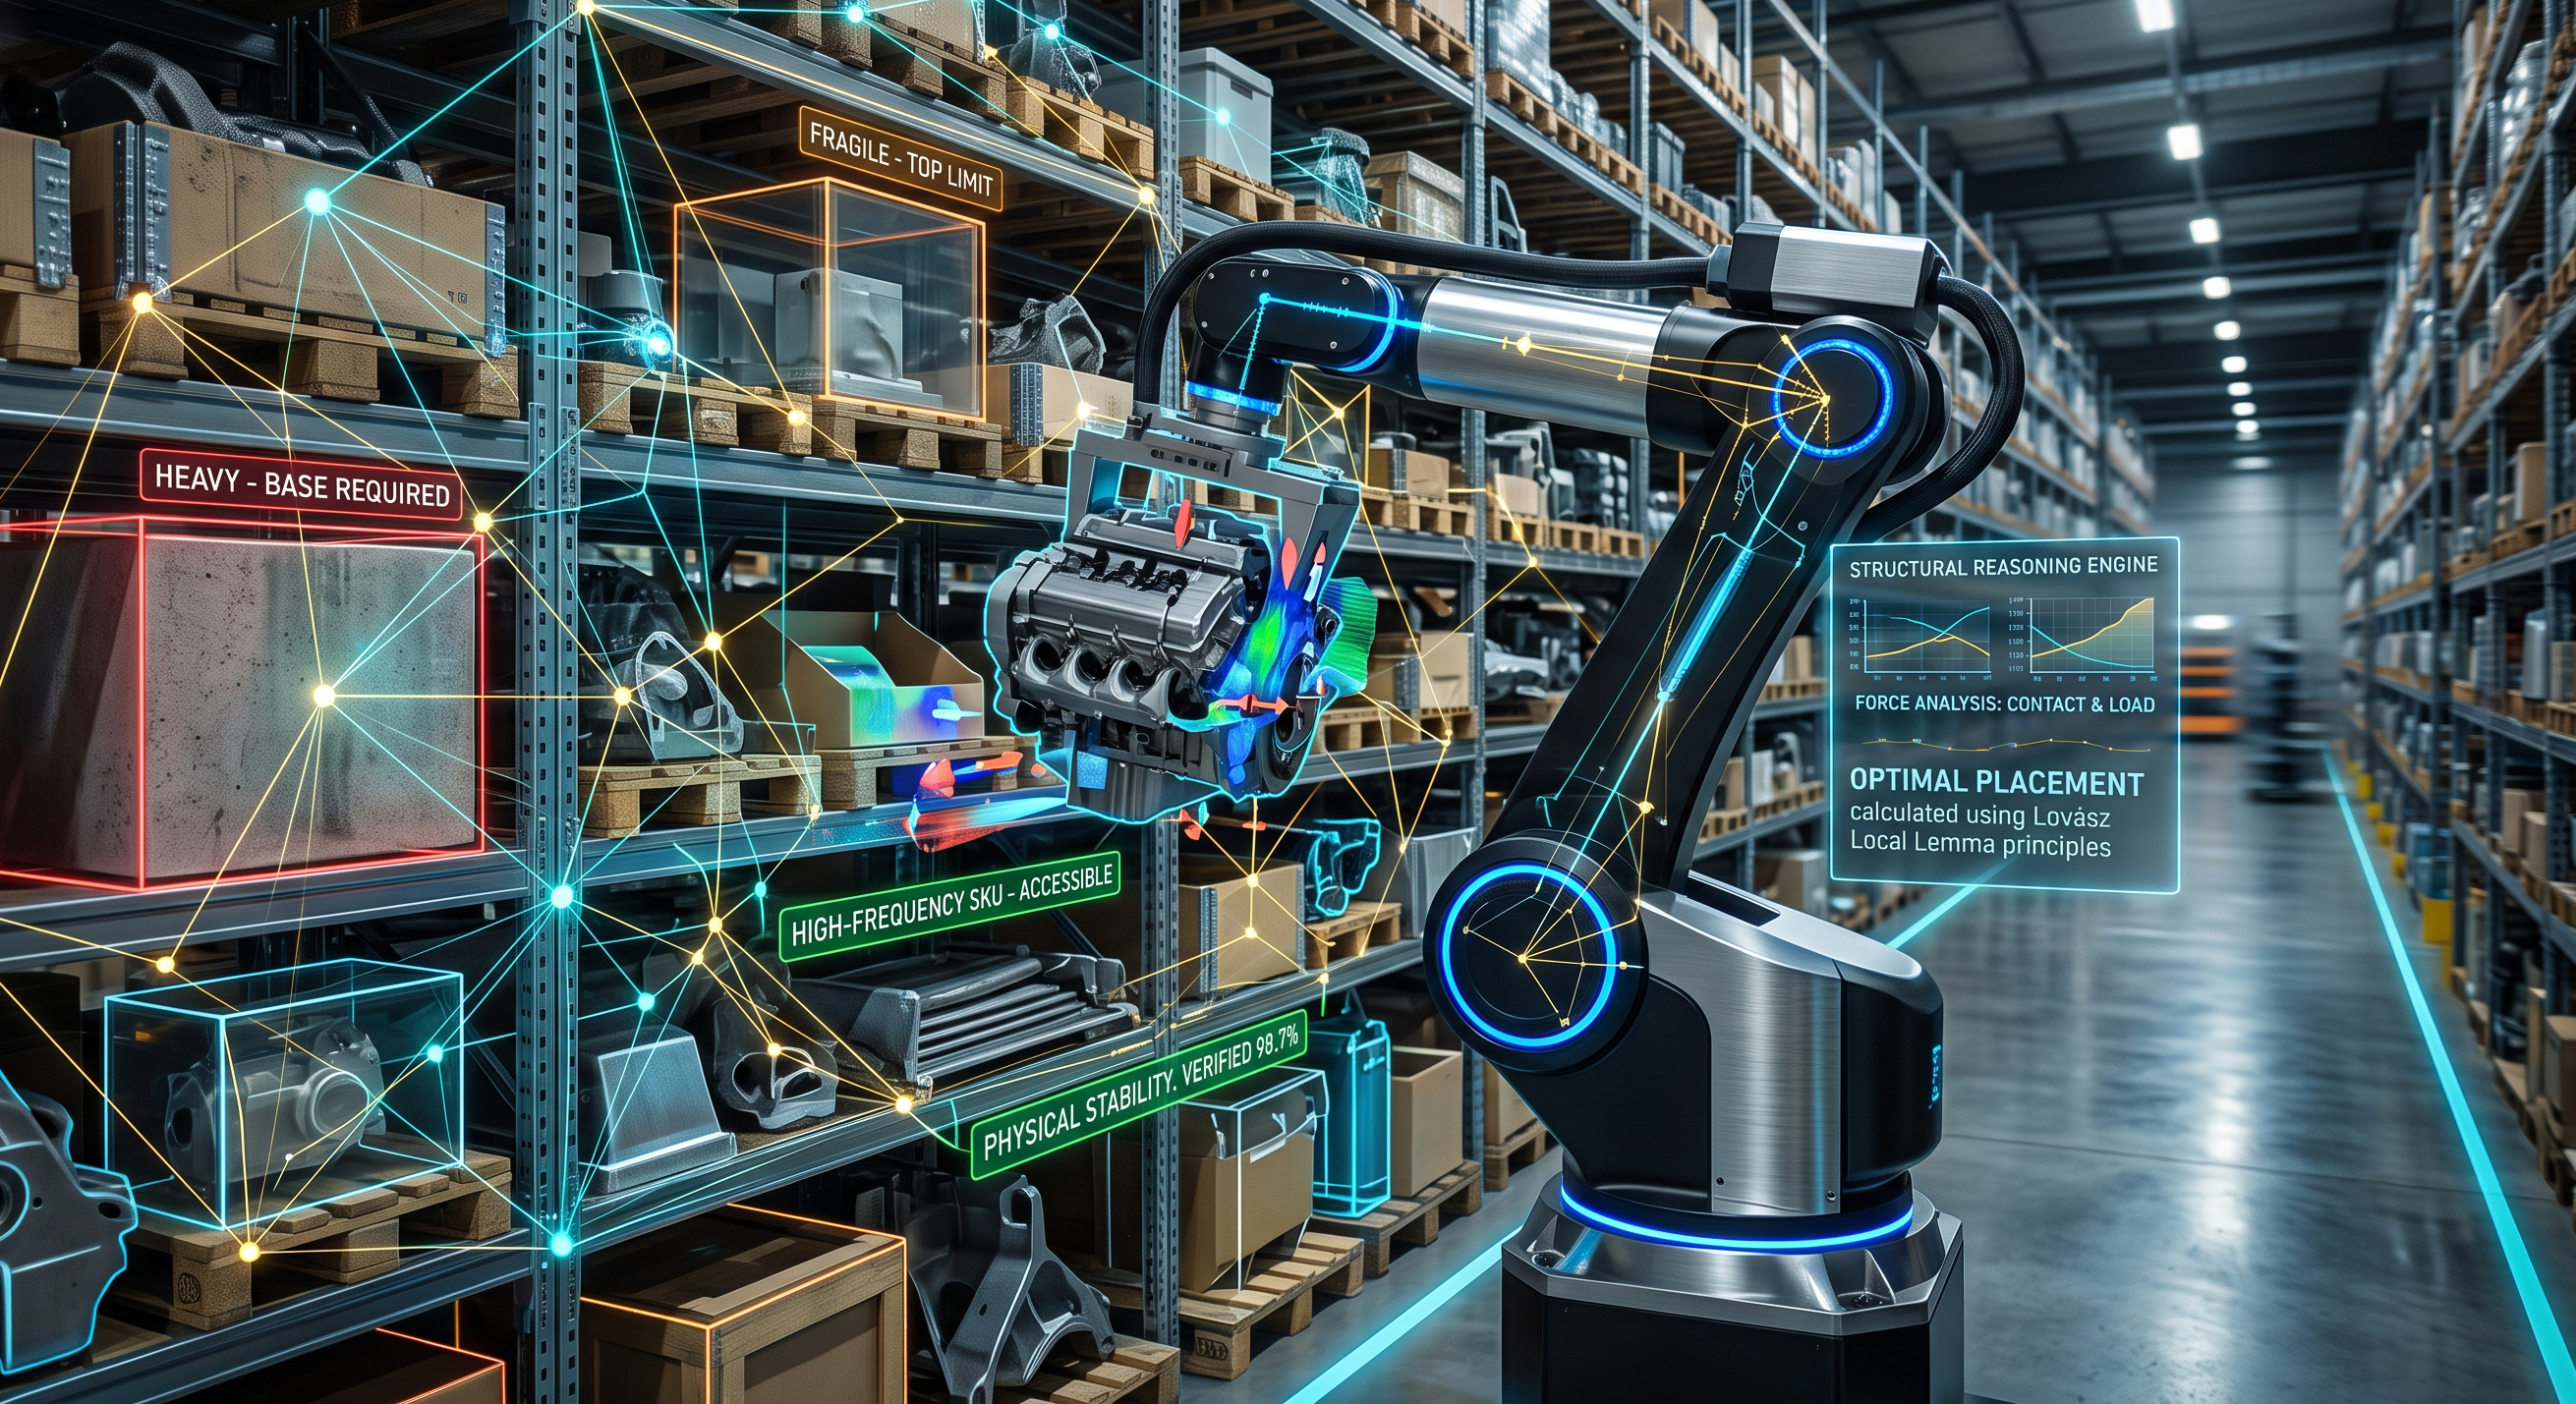
The biggest gains in a reasoning system therefore do not always come from making the underlying model larger. They can come from giving it better structure to reason within. The idea has precedent well outside AI. In combinatorics, results building on the Lovász Local Lemma show how understanding dependencies between constraints can make enormous search spaces tractable without exhaustively exploring them.
Structure can matter more than size.
The same principle plays out on a warehouse floor. Picture three dimensional Tetris, with thousands of differently shaped items arriving in random order. Every placement changes what can happen next. A heavy crate constrains what can sit beneath it. A fragile item limits what can go above it. A frequently picked SKU needs to remain accessible.
The number of possible arrangements is enormous, but most decisions interact with only a small neighborhood of the overall problem. Once a model understands which relationships actually matter, it can stop exploring possibilities that were never viable in the first place.
The goal is not to memorize or search through every possibility. It is to understand the structure well enough to reason through the ones that matter.
04.2
Reasoning with Physics
Physics should not sit outside the model as a simulator consulted after the fact. It can shape both how the model learns and how it reasons at inference time.
During training, geometry, contact, forces, motion, and material behavior can be encoded through physics informed losses, constraints, and priors. The model is not rewarded only for matching a labeled answer. Its predictions can also be penalized when they violate geometric consistency, physical feasibility, or known relationships between objects and actions. This helps the model learn representations organized around how the world actually behaves.
At inference time, those same principles help constrain reasoning. A predicted grasp can be evaluated for reachability and stability. A motion can be checked against kinematic and dynamic limits. A proposed interaction can be evaluated for collision, contact, and physical plausibility before it becomes an action.
This changes what the model has to learn from examples. Instead of discovering every physical relationship statistically from data alone, learning is guided toward solutions consistent with the underlying structure of the world.
Data teaches the model the task. Physics shapes what it learns and helps define the space of valid solutions.
04.3
300 Examples, Not Millions
Robots cannot depend on endless field trials or massive data collection pipelines. Every real-world example carries cost, time, and operational risk, making brute-force learning especially expensive.
When a model already understands geometry, physical relationships, and how actions affect the world, a new deployment does not require learning those principles again. The data only needs to teach what is specific to the task: the objects, environment, operating conditions, tolerances, and desired behavior.
This changes the role of training data. Instead of trying to statistically cover every possible edge case, a few hundred carefully chosen examples can adapt the model to a new task, while its underlying physical reasoning carries across configurations it has never seen.
In practice, this can mean roughly 300 examples instead of hundreds of thousands or millions.
The goal is not to collect enough data to represent every possible physical situation. It is to build enough understanding that the model can reason through situations it has never seen.
05
From Demos to Deployment
A robotic demo proves that a machine can perform a task once. Deployment requires it to perform that task thousands of times, across changing conditions, unfamiliar situations, and the long tail of the physical world.
This is where the principles of Physical AI come together. World reasoning enables adaptation, physics provides structure beyond the training data, compositional architectures make systems easier to extend and validate, and real-time intelligence keeps the loop running on the machine itself. Together, these capabilities move robots beyond controlled demonstrations into the environments where physical work actually happens.
05.1
Warehouses & Logistics
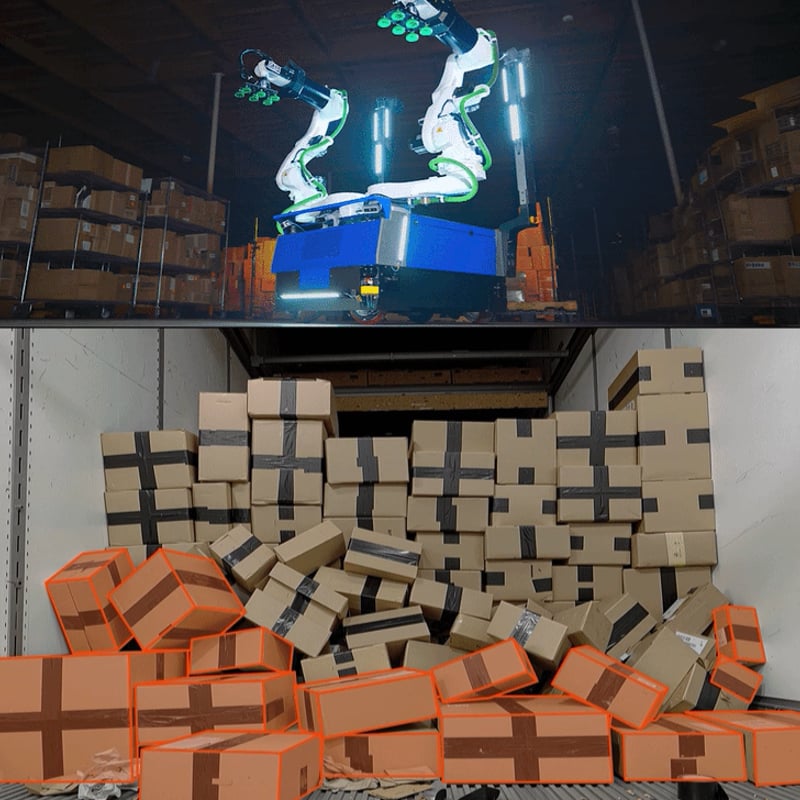
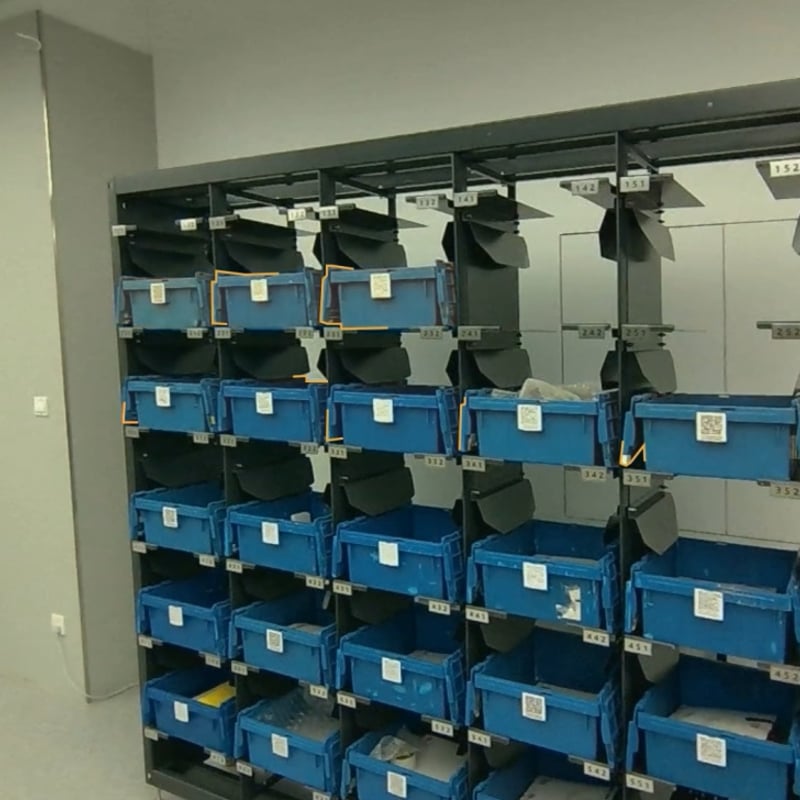
Warehouses combine high throughput with enormous physical variability. In trailer unloading, packages arrive at different angles, deform under load, occlude one another, and shift as each item is removed. In storage and picking, every placement affects what remains accessible next.
Physical AI can reason through these changing configurations rather than depending on predefined box types or fixed sequences. It can evaluate geometry, stability, accessibility, and the consequences of each action in real time, allowing automation to extend into tasks that have historically resisted rigid programming.
05.2
Heavy Equipment & Field Operations
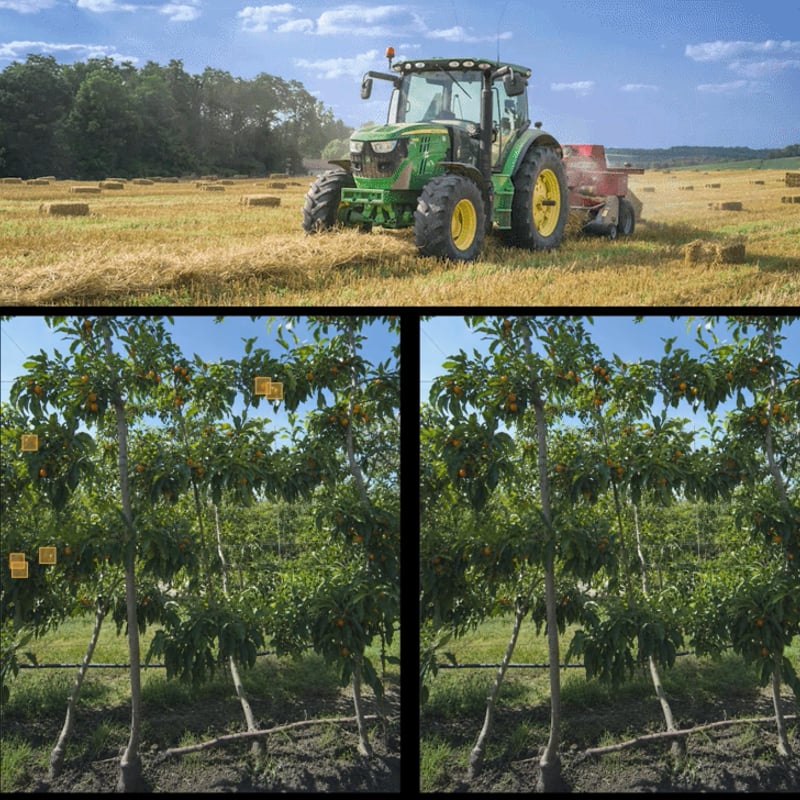
Heavy equipment operates in environments that rarely stay the same. Farms change with weather and seasons. Construction sites evolve by the hour. Terrain shifts, obstacles move, visibility changes, and people and machines continually enter and leave the workspace.
Physical AI allows agricultural and construction machines to understand these changing surroundings, reason about terrain, geometry, obstacles, and safe operating space, and adapt their behavior in real time. The same underlying intelligence can support perception, navigation, safety, and task execution across machines and environments without requiring every condition to be explicitly programmed.
05.3
Inspection & Physical Condition
Inspection requires more than recognizing whether an object looks like a known example. Parts vary, defects appear in unfamiliar forms, surfaces reflect and deform, and the same asset can look very different as lighting, viewpoint, wear, and operating conditions change.
Physical AI can reason about geometry, dimensions, relationships between components, and changes in physical condition. This allows the same underlying intelligence to measure, count, inspect, and verify objects and assets across manufacturing, equipment, and infrastructure, adapting to new conditions without rebuilding the system for every inspection task.
05.4
Manufacturing & Assembly
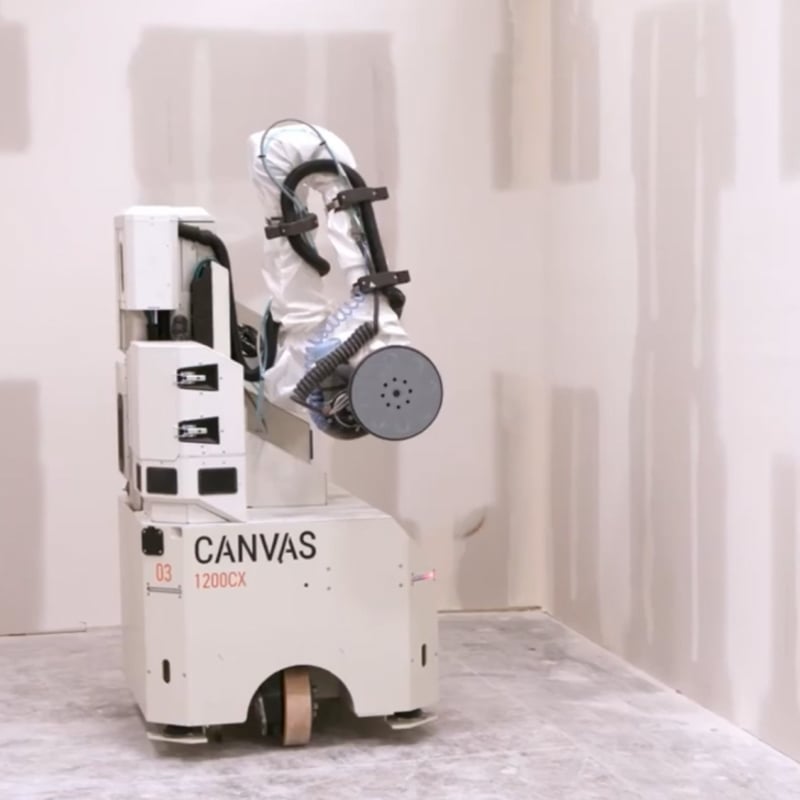
Manufacturing demands precision, but the hardest tasks also require adaptation. Parts arrive with small variations, materials bend and deform, tolerances are tight, and successful assembly often depends on understanding contact and force rather than simply reaching a predefined position.
Physical AI enables robots to reason about geometry, alignment, contact, and material behavior as they work. This extends automation into tasks such as variable part assembly, insertion, fastening, cable and wire handling, and other precision manipulation where rigid programming breaks down.
06
Building the Next Generation of Physical AI
The next generation of intelligent machines will not be built by scaling data and model size alone. Physical AI requires systems that understand how the world evolves, reason through physics, learn efficiently, and remain reliable and interpretable as they make decisions.
That intelligence must also operate where the physical work happens, in real time and at the edge, without depending on constant cloud connectivity. The opportunity is to build machines that combine learning with structure, reasoning with reliability, and increasingly capable models with systems we can understand and trust.
That is how Physical AI moves from impressive demonstrations to intelligent machines that can operate across the complexity of the real world.
07
Resources for Builders
Dig deeper into the research, frameworks, and perspectives shaping Physical AI.
- Transparency & Accountability in Generative AI for Robotics — Ransalu Senanayake
- Inside the VLAM Stack: Building Generalist Agents — Honglak Lee
- Generative AI in Robotics: Doing More with Less Data
- Infrastructure of Large-Scale AI — Aditya Jami
- Model Concept Protocol — Jiquan Ngiam
- Designing Multimodal Robots for an Unstructured World — Kofi Asante
- Generative AI for Robotics: From Demos to Deployment
- Forbes: From Words To Work — Generative AI's Leap Into The Physical World